第一步下载模型
yolov8 https://github.com/ultralytics/ultralytics
第二步训练模型
yolo train data=自定义.yaml model=yolov8s.pt pretrained=True project=Train_640 name=n_pretrain epochs=1000 batch=4 device=0 patience=0 lr0=0.001 lrf=0.001第三步转换模型onnx
1、修改head.py
class Detect(nn.Module):

...

   #新增forward
   def forward(self, x):
        bboxes = [self.cv2[i](x[i]).permute(0, 2, 3, 1).contiguous() for i in range(self.nl)]
        clses = [self.cv3[i](x[i]).permute(0, 2, 3, 1).contiguous() for i in range(self.nl)]
        return (bboxes, clses)

   #重命名 forward -> forward_
   def forward_(self, x):
        """Concatenates and returns predicted bounding boxes and class probabilities."""
        if self.end2end:
            return self.forward_end2end(x)

        for i in range(self.nl):
            x[i] = torch.cat((self.cv2[i](x[i]), self.cv3[i](x[i])), 1)
        if self.training:  # Training path
            return x
        y = self._inference(x)
        return y if self.export else (y, x)

...

class Segment(Detect)
   #新增forward
   def forward(self, x):
        p = self.proto(x[0]).permute(0, 2, 3, 1).contiguous()  # mask protos
        results = []
        for i in range(self.nl):
            box = self.cv2[i](x[i]).permute(0, 2, 3, 1).contiguous()
            cls = self.cv3[i](x[i]).permute(0, 2, 3, 1).contiguous()
            mask = self.cv4[i](x[i]).permute(0, 2, 3, 1).contiguous()
            results.append(cls)
            results.append(box)
            results.append(mask)
        results.append(p)
        return tuple(results)

    #重命名 forward -> forward_
    def forward_(self, x):
        """Return model outputs and mask coefficients if training, otherwise return outputs and mask coefficients."""
        p = self.proto(x[0])  # mask protos
        bs = p.shape[0]  # batch size

        mc = torch.cat([self.cv4[i](x[i]).view(bs, self.nm, -1) for i in range(self.nl)], 2)  # mask coefficients
        x = Detect.forward(self, x)
        if self.training:
            return x, mc, p
        return (torch.cat([x, mc], 1), p) if self.export else (torch.cat([x[0], mc], 1), (x[1], mc, p))
2、导出ONNX
from ultralytics import YOLO

YOLO('H:/git/ultralytics/volleyball/best.pt').export(imgsz=640, format='onnx', simplify=True, opset=11)
第四步Docker环境准备 参考:
RDK X5 算法工具链社区手册:https://developer.d-robotics.cc/api/v1/fileData/x5_doc-v126cn/index.html
1、下载
wget -c ftp://x5ftp@vrftp.horizon.ai/OpenExplorer/v1.2.6_release/docker_openexplorer_ubuntu_20_x5_cpu_v1.2.6.tar.gz --ftp-password=x5ftp@123$%
2、加载
docker load --input docker_openexplorer_ubuntu_20_x5_cpu_v1.2.6.tar.gz
3、查看
docker image list
4、挂载
docker run -it -v "H:\horizonx5\codes":/data/horizon_x5/codes -v "H:\horizonx5\data":/data/horizon_x5/data openexplorer/ai_toolchain_ubuntu_20_x5_cpu:v1.2.6第五步转换模型onnx
1、检查模型
hb_mapper checker --model-type onnx --march bayes-e --model yolov8.onnx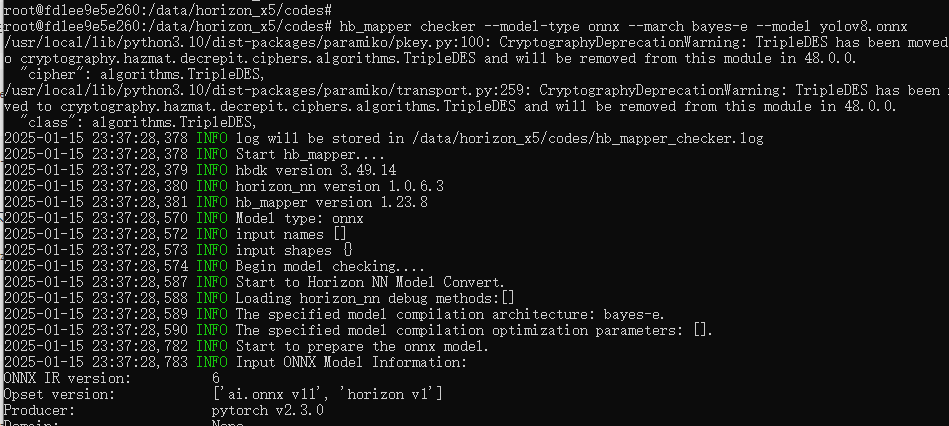
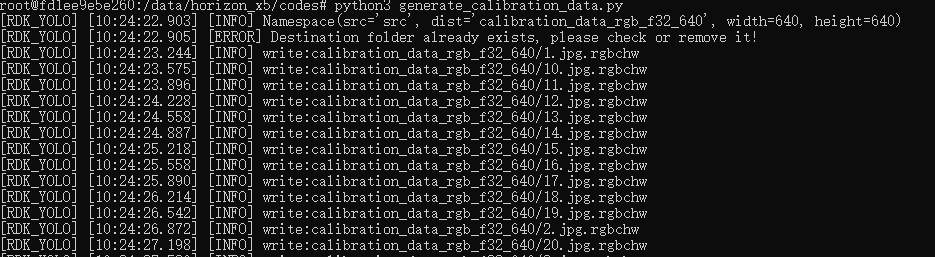
2、验证集准备 生成校准数据集 使用 generate_calibration_data.py
https://github.com/D-Robotics/rdk_model_zoo/tree/main/demos/tools/generate_calibration_data
3、转换模型
转换配置文件 yolov8_onnx_convert.yaml
# 模型转化相关的参数
model_parameters:
  # 必选参数
  # Onnx浮点网络数据模型文件, 例如:onnx_model: './horizon_x3_onnx.onnx'
  onnx_model: './yolov8.onnx'
  march: "bayes-e"
  layer_out_dump: False
  working_dir: 'model_output'
  output_model_file_prefix: 'horizon_x5'
  node_info: {"/model.10/m/m.0/attn/Softmax": {'ON': 'BPU','InputType': 'int16','OutputType': 'int16'}}

# 模型输入相关参数
input_parameters:
  input_name: ""
  input_type_rt: 'nv12'
  input_type_train: 'rgb'
  input_layout_train: 'NCHW'
  norm_type: 'data_scale'
  scale_value: 0.003921568627451

# 模型量化相关参数
calibration_parameters:
  # 必选参数, 使用2.1中的图片路径
  cal_data_dir: './calibration_data_rgb_f32_640'
  cal_data_type: 'float32'
# 编译器相关参数
compiler_parameters:
  compile_mode: 'latency'
  debug: False
  # core_num: 2
  optimize_level: 'O3'
转换命令执行
hb_mapper makertbin --config yolov8_onnx_convert.yaml --model-type onnx
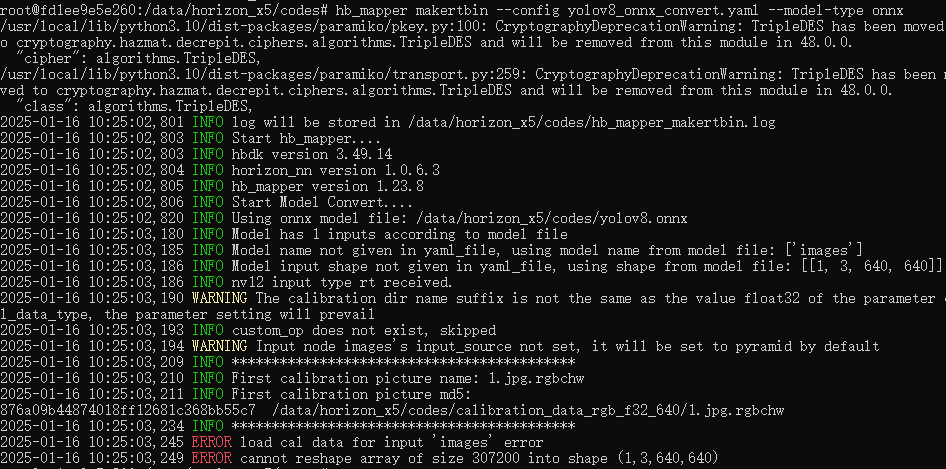
此处报错:
2025-01-16 10:25:03,245 ERROR load cal data for input 'images' error
2025-01-16 10:25:03,249 ERROR cannot reshape array of size 307200 into shape (1,3,640,640)