r more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289148.039649269] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289148.040098184] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [ERROR] [1775289152.646088052] [hobot_codec_encoder]: Hobot_Codec has not received image for more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289153.039641081] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289153.040089038] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [ERROR] [1775289157.646072240] [hobot_codec_encoder]: Hobot_Codec has not received image for more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289158.039633685] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289158.040192225] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [ERROR] [1775289162.646062261] [hobot_codec_encoder]: Hobot_Codec has not received image for more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289163.039624831] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289163.040077496] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [ERROR] [1775289167.646043323] [hobot_codec_encoder]: Hobot_Codec has not received image for more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289168.039614477] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289168.040081476] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [ERROR] [1775289172.646038761] [hobot_codec_encoder]: Hobot_Codec has not received image for more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289173.039599789] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289173.040071080] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [ERROR] [1775289177.646016365] [hobot_codec_encoder]: Hobot_Codec has not received image for more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289178.039589060] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289178.040043975] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [ERROR] [1775289182.646011802] [hobot_codec_encoder]: Hobot_Codec has not received image for more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289183.039576997] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289183.040040538] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [ERROR] [1775289187.646002615] [hobot_codec_encoder]: Hobot_Codec has not received image for more than 5 seconds! Please check whether the image publisher still exists by ‘ros2 topic info /hbmem_img’!
[websocket-4] [ERROR] [1775289188.039556060] [websocket]: Websocket did not receive image data! Please check whether the image publisher still exists by ‘ros2 topic info /image’!
[websocket-4] [ERROR] [1775289188.040021392] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
^C[WARNING] [launch]: user interrupted with ctrl-c (SIGINT)
[INFO] [hobot_codec_republish-2]: process has finished cleanly [pid 5750]
[INFO] [websocket-4]: process has finished cleanly [pid 5754]
[INFO] [example-3]: process has finished cleanly [pid 5752]
sunrise@ubuntu:~/yiqiang_ws$ ros2 launch origincar_bringup usb_websocket_display.launch.py
[INFO] [launch]: All log files can be found below /home/sunrise/.ros/log/2026-04-04-15-54-04-300758-ubuntu-8139
[INFO] [launch]: Default logging verbosity is set to INFO
config_file_path is /opt/tros/humble/lib/hobot_usb_cam/config/usb_camera_calibration.yaml
Hobot shm pkg enables zero-copy with fastrtps profiles file: /opt/tros/humble/lib/hobot_shm/config/shm_fastdds.xml
Hobot shm pkg sets RMW_FASTRTPS_USE_QOS_FROM_XML: 1
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
webserver has launch
config_file_path is /opt/tros/humble/lib/hobot_usb_cam/config/usb_camera_calibration.yaml
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
webserver has launch
[INFO] [hobot_usb_cam-1]: process started with pid [8164]
[INFO] [hobot_codec_republish-2]: process started with pid [8166]
[INFO] [example-3]: process started with pid [8168]
[INFO] [websocket-4]: process started with pid [8170]
[INFO] [image_transport_node-5]: process started with pid [8172]
[hobot_codec_republish-2] [WARN] [1775289245.004794437] [hobot_codec_decoder]: Parameters:
[hobot_codec_republish-2] sub_topic: /image
[hobot_codec_republish-2] pub_topic: /hbmem_img
[hobot_codec_republish-2] channel: 1
[hobot_codec_republish-2] in_mode: ros
[hobot_codec_republish-2] out_mode: shared_mem
[hobot_codec_republish-2] in_format: jpeg
[hobot_codec_republish-2] out_format: nv12
[hobot_codec_republish-2] jpg_quality: 60.00
[hobot_codec_republish-2] input_framerate: 30
[hobot_codec_republish-2] output_framerate: -1
[hobot_codec_republish-2] dump_output: false
[hobot_codec_republish-2] dump_file_prefix: ./dump_codec_output
[hobot_codec_republish-2] dump_frame_count: -1 (unlimited)
[hobot_codec_republish-2] [WARN] [1775289245.012680710] [HobotCodecImpl]: platform x5
[hobot_usb_cam-1] [WARN] [1775289245.145168480] [hobot_usb_cam]: framerate: 30
[hobot_usb_cam-1] [WARN] [1775289245.145748896] [hobot_usb_cam]: pixel_format_name: mjpeg
[hobot_usb_cam-1] [WARN] [1775289245.169925297] [hobot_usb_cam]: Camera calibration file: [/opt/tros/humble/lib/hobot_usb_cam/config/usb_camera_calibration.yaml] does not exist!
[hobot_usb_cam-1] If you need calibration msg, please make sure the calibration file path is correct and the calibration file exists!
[hobot_usb_cam-1] [WARN] [1775289245.266037903] [hobot_usb_cam]: This devices supproted formats:
[hobot_usb_cam-1] [WARN] [1775289245.266398735] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266468027] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266509194] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266547360] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266586068] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266623152] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266660193] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266697026] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266734151] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266771943] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266809110] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266845818] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266882526] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266919276] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266955901] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.266992692] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267029151] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267065734] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267103067] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267139734] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267176400] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267213317] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267249858] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267286317] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267323317] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267360567] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267397483] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267434066] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267470941] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267507566] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267544358] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267581441] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267618524] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267655983] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267693066] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267731982] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267769649] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267806690] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267843440] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267880690] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267918857] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267956190] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.267993023] [hobot_usb_cam]: YUYV 4:2:2: 640 x 480 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268029648] [hobot_usb_cam]: YUYV 4:2:2: 640 x 480 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268066940] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268103398] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268245231] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268292898] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268331773] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268369064] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268406106] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268443439] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268480731] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268516814] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268553564] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268589730] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268626230] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268663647] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268700563] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268737272] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268779813] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268817188] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268854063] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268890855] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268927896] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.268964813] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269005188] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269042479] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269079687] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269117062] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269153562] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269190312] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269227312] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269264145] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269300979] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269340062] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269376978] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269414228] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269450853] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269487020] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269524228] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269561020] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269598186] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269635394] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269672686] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269709394] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269746186] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269783061] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269820394] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269857561] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269899894] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289245.269937685] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (5 Hz)
[example-3] [WARN] [1775289245.348389333] [dnn_example_node]: Parameter:
[example-3] feed_type(0:local, 1:sub): 1
[example-3] image: config/test.jpg
[example-3] image_type: 0
[example-3] dump_render_img: 0
[example-3] is_shared_mem_sub: 1
[example-3] config_file: config/fcosworkconfig.json
[example-3] msg_pub_topic_name: hobot_dnn_detection
[example-3] info_msg_pub_topic_name: hobot_dnn_detection_info
[example-3] ros_img_topic_name: /image
[example-3] sharedmem_img_topic_name: /hbmem_img
[example-3] [WARN] [1775289245.349318498] [dnn_example_node]: Load [80] class types from file [config/coco.list]
[example-3] [WARN] [1775289245.349494747] [dnn_example_node]: Parameter:
[example-3] model_file_name: /opt/hobot/model/x5/basic/fcos_512x512_nv12.bin
[example-3] model_name:
[example-3] [WARN] [1775289245.349633997] [dnn_example_node]: model_file_name_: /opt/hobot/model/x5/basic/fcos_512x512_nv12.bin, task_num: 4
[example-3] [BPU_PLAT]BPU Platform Version(1.3.6)! soc info(x5)
[example-3] [HBRT] set log level as 0. version = 3.15.55.0
[example-3] [DNN] Runtime version = 1.24.5_(3.15.55 HBRT)
[image_transport_node-5] [INFO] [1775289245.391690231] [Nv122BGR]: Nv122BGR
[websocket-4] [WARN] [1775289245.392120147] [websocket]:
[websocket-4] Parameter:
[websocket-4] image_topic: /image
[websocket-4] image_type: mjpeg
[websocket-4] only_show_image: 0
[websocket-4] smart_topic: hobot_dnn_detection
[websocket-4] output_fps: 0
[hobot_codec_republish-2] [WARN] [1775289245.402802788] [hobot_codec_decoder]: New subscription discovered on topic ‘/hbmem_img’, requesting incompatible QoS. No messages will be sent to it. Last incompatible policy: RELIABILITY_QOS_POLICY
[image_transport_node-5] [WARN] [1775289245.426907565] [Nv122BGR]: New publisher discovered on topic ‘/hbmem_img’, offering incompatible QoS. No messages will be sent to it. Last incompatible policy: RELIABILITY_QOS_POLICY
[example-3] [A][DNN][packed_model.cpp:247]Model [HorizonRT] The model builder version = 1.23.5
[example-3] [WARN] [1775289245.590402470] [dnn_example_node]: Get model name: fcos_efficientnetb0_512x512_nv12 from load model.
[example-3] [WARN] [1775289245.590579261] [dnn_example_node]: Create ai msg publisher with topic_name: hobot_dnn_detection
[example-3] [WARN] [1775289245.605790142] [dnn_example_node]: Create img hbmem_subscription with topic_name: /hbmem_img
[example-3] [WARN] [1775289246.213526790] [dnn_example_node]: Loaned messages are only safe with const ref subscription callbacks. If you are using any other kind of subscriptions, set the ROS_DISABLE_LOANED_MESSAGES environment variable to 1 (the default).
[example-3] [WARN] [1775289246.213871330] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 0, stamp: 1775289246_7664000, data size: 460800, comm delay [206.1830]ms
[example-3] [WARN] [1775289247.238263952] [dnn_example_node]: Sub img fps: 32.90, Smart fps: 32.90, recved img time delay ms: 159, pre process time ms: 3, infer time ms: 3, post process time ms: 7, pipeline time ms: 175
[example-3] [WARN] [1775289248.270539638] [dnn_example_node]: Sub img fps: 30.24, Smart fps: 30.24, recved img time delay ms: 164, pre process time ms: 4, infer time ms: 4, post process time ms: 13, pipeline time ms: 187
[example-3] [WARN] [1775289249.241199928] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 93, stamp: 1775289249_75349000, data size: 460800, comm delay [165.8346]ms
[example-3] [WARN] [1775289249.293534513] [dnn_example_node]: Sub img fps: 30.19, Smart fps: 30.19, recved img time delay ms: 166, pre process time ms: 5, infer time ms: 4, post process time ms: 9, pipeline time ms: 186
[example-3] [W][DNN]bpu_model_info.cpp:491]Version Model: fcos_efficientnetb0_512x512_nv12. Inconsistency between the hbrt library version 3.15.55.0 and the model build version 3.15.47.0 detected, in order to ensure correct model results, it is recommended to use compilation tools and the BPU SDK from the same OpenExplorer package.
[hobot_codec_republish-2] [WARN] [1775289250.064049943] [hobot_codec_decoder]: Pub img fps [23.71]
[example-3] [WARN] [1775289250.324315078] [dnn_example_node]: Sub img fps: 30.27, Smart fps: 30.21, recved img time delay ms: 166, pre process time ms: 5, infer time ms: 4, post process time ms: 14, pipeline time ms: 193
[example-3] [WARN] [1775289251.345054000] [dnn_example_node]: Sub img fps: 30.39, Smart fps: 30.39, recved img time delay ms: 162, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 189
[example-3] [WARN] [1775289252.276956548] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 185, stamp: 1775289252_111029000, data size: 460800, comm delay [165.9117]ms
[example-3] [WARN] [1775289252.368966956] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.30, recved img time delay ms: 165, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 193
[example-3] [WARN] [1775289253.391881539] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.30, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 193
[example-3] [WARN] [1775289254.401138613] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.42, recved img time delay ms: 166, pre process time ms: 5, infer time ms: 3, post process time ms: 3, pipeline time ms: 179
[hobot_codec_republish-2] [WARN] [1775289255.080036551] [hobot_codec_decoder]: Pub img fps [30.31]
[example-3] [WARN] [1775289255.312504501] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 277, stamp: 1775289255_146685000, data size: 460800, comm delay [165.8039]ms
[example-3] [WARN] [1775289255.420685287] [dnn_example_node]: Sub img fps: 30.42, Smart fps: 30.42, recved img time delay ms: 162, pre process time ms: 5, infer time ms: 3, post process time ms: 3, pipeline time ms: 174
[example-3] [WARN] [1775289256.458527961] [dnn_example_node]: Sub img fps: 30.27, Smart fps: 30.16, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 4, post process time ms: 12, pipeline time ms: 192
[example-3] [WARN] [1775289257.468265492] [dnn_example_node]: Sub img fps: 30.33, Smart fps: 30.45, recved img time delay ms: 166, pre process time ms: 4, infer time ms: 3, post process time ms: 3, pipeline time ms: 178
[example-3] [WARN] [1775289258.344316755] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 369, stamp: 1775289258_182440000, data size: 460800, comm delay [161.8600]ms
[example-3] [WARN] [1775289258.502682839] [dnn_example_node]: Sub img fps: 30.39, Smart fps: 30.27, recved img time delay ms: 161, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 188
[example-3] [WARN] [1775289259.515032406] [dnn_example_node]: Sub img fps: 30.27, Smart fps: 30.33, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 3, post process time ms: 3, pipeline time ms: 181
[hobot_codec_republish-2] [WARN] [1775289260.095616701] [hobot_codec_decoder]: Pub img fps [30.31]
[example-3] [WARN] [1775289260.552411414] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.21, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 4, post process time ms: 14, pipeline time ms: 194
[example-3] [WARN] [1775289261.348107784] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 460, stamp: 1775289261_182108000, data size: 460800, comm delay [165.9837]ms
[example-3] [WARN] [1775289261.564474773] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.30, recved img time delay ms: 165, pre process time ms: 6, infer time ms: 4, post process time ms: 3, pipeline time ms: 182
[example-3] [WARN] [1775289262.595069963] [dnn_example_node]: Sub img fps: 30.42, Smart fps: 30.39, recved img time delay ms: 163, pre process time ms: 5, infer time ms: 4, post process time ms: 14, pipeline time ms: 190
[example-3] [WARN] [1775289263.602579999] [dnn_example_node]: Sub img fps: 30.48, Smart fps: 30.57, recved img time delay ms: 164, pre process time ms: 2, infer time ms: 3, post process time ms: 6, pipeline time ms: 177
[example-3] [WARN] [1775289264.351586355] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 551, stamp: 1775289264_185794000, data size: 460800, comm delay [165.7764]ms
[example-3] [WARN] [1775289264.623829003] [dnn_example_node]: Sub img fps: 30.27, Smart fps: 30.27, recved img time delay ms: 164, pre process time ms: 2, infer time ms: 3, post process time ms: 3, pipeline time ms: 174
[hobot_codec_republish-2] [WARN] [1775289265.111049852] [hobot_codec_decoder]: Pub img fps [30.31]
[example-3] [WARN] [1775289265.661260469] [dnn_example_node]: Sub img fps: 30.21, Smart fps: 30.19, recved img time delay ms: 165, pre process time ms: 4, infer time ms: 4, post process time ms: 13, pipeline time ms: 188
[example-3] [WARN] [1775289266.686631755] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.24, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 193
[example-3] [WARN] [1775289267.355271967] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 642, stamp: 1775289267_189494000, data size: 460800, comm delay [165.7617]ms
[example-3] [WARN] [1775289267.708996298] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.27, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 4, post process time ms: 11, pipeline time ms: 191
[example-3] [WARN] [1775289268.725237022] [dnn_example_node]: Sub img fps: 30.48, Smart fps: 30.57, recved img time delay ms: 163, pre process time ms: 3, infer time ms: 3, post process time ms: 13, pipeline time ms: 184
[example-3] [WARN] [1775289269.741963453] [dnn_example_node]: Sub img fps: 30.36, Smart fps: 30.30, recved img time delay ms: 160, pre process time ms: 3, infer time ms: 3, post process time ms: 6, pipeline time ms: 176
[hobot_codec_republish-2] [WARN] [1775289270.122579471] [hobot_codec_decoder]: Pub img fps [30.33]
[example-3] [WARN] [1775289270.385458850] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 734, stamp: 1775289270_225171000, data size: 460800, comm delay [160.2803]ms
[example-3] [WARN] [1775289270.760856296] [dnn_example_node]: Sub img fps: 30.36, Smart fps: 30.42, recved img time delay ms: 163, pre process time ms: 2, infer time ms: 3, post process time ms: 6, pipeline time ms: 175
[example-3] [WARN] [1775289271.791260737] [dnn_example_node]: Sub img fps: 30.27, Smart fps: 30.21, recved img time delay ms: 163, pre process time ms: 3, infer time ms: 3, post process time ms: 10, pipeline time ms: 182
[example-3] [WARN] [1775289272.816345648] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.33, recved img time delay ms: 164, pre process time ms: 2, infer time ms: 3, post process time ms: 13, pipeline time ms: 184
[example-3] [WARN] [1775289273.388158464] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 825, stamp: 1775289273_224795000, data size: 460800, comm delay [163.3560]ms
[example-3] [WARN] [1775289273.845848924] [dnn_example_node]: Sub img fps: 30.21, Smart fps: 30.13, recved img time delay ms: 162, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 189
[example-3] [WARN] [1775289274.858067491] [dnn_example_node]: Sub img fps: 30.27, Smart fps: 30.33, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 3, post process time ms: 3, pipeline time ms: 182
[hobot_codec_republish-2] [WARN] [1775289275.137399456] [hobot_codec_decoder]: Pub img fps [30.32]
[example-3] [WARN] [1775289275.886302395] [dnn_example_node]: Sub img fps: 30.39, Smart fps: 30.42, recved img time delay ms: 164, pre process time ms: 4, infer time ms: 3, post process time ms: 12, pipeline time ms: 186
[example-3] [WARN] [1775289276.393389489] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 916, stamp: 1775289276_228535000, data size: 460800, comm delay [164.8468]ms
[example-3] [WARN] [1775289276.901197121] [dnn_example_node]: Sub img fps: 30.33, Smart fps: 30.33, recved img time delay ms: 163, pre process time ms: 4, infer time ms: 3, post process time ms: 4, pipeline time ms: 177
[example-3] [WARN] [1775289277.929003844] [dnn_example_node]: Sub img fps: 30.27, Smart fps: 30.27, recved img time delay ms: 162, pre process time ms: 5, infer time ms: 3, post process time ms: 6, pipeline time ms: 180
[example-3] [WARN] [1775289278.948987866] [dnn_example_node]: Sub img fps: 30.42, Smart fps: 30.42, recved img time delay ms: 164, pre process time ms: 3, infer time ms: 3, post process time ms: 7, pipeline time ms: 180
[example-3] [WARN] [1775289279.395453551] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 1007, stamp: 1775289279_232229000, data size: 460800, comm delay [163.2173]ms
[example-3] [WARN] [1775289279.980224697] [dnn_example_node]: Sub img fps: 30.33, Smart fps: 30.27, recved img time delay ms: 163, pre process time ms: 3, infer time ms: 4, post process time ms: 14, pipeline time ms: 188
[hobot_codec_republish-2] [WARN] [1775289280.151162456] [hobot_codec_decoder]: Pub img fps [30.32]
[example-3] [WARN] [1775289280.986842397] [dnn_example_node]: Sub img fps: 30.39, Smart fps: 30.48, recved img time delay ms: 161, pre process time ms: 2, infer time ms: 3, post process time ms: 3, pipeline time ms: 170
[example-3] [WARN] [1775289282.016372320] [dnn_example_node]: Sub img fps: 30.27, Smart fps: 30.24, recved img time delay ms: 165, pre process time ms: 3, infer time ms: 3, post process time ms: 7, pipeline time ms: 181
[example-3] [WARN] [1775289282.397724974] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 1098, stamp: 1775289282_231896000, data size: 460800, comm delay [165.8130]ms
[example-3] [WARN] [1775289283.044477731] [dnn_example_node]: Sub img fps: 30.19, Smart fps: 30.19, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 3, post process time ms: 7, pipeline time ms: 185
[example-3] [WARN] [1775289284.070910631] [dnn_example_node]: Sub img fps: 30.39, Smart fps: 30.39, recved img time delay ms: 164, pre process time ms: 4, infer time ms: 4, post process time ms: 13, pipeline time ms: 187
[example-3] [WARN] [1775289285.089875647] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.30, recved img time delay ms: 162, pre process time ms: 6, infer time ms: 3, post process time ms: 8, pipeline time ms: 182
[hobot_codec_republish-2] [WARN] [1775289285.166675661] [hobot_codec_decoder]: Pub img fps [30.31]
[example-3] [WARN] [1775289285.400480595] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 1189, stamp: 1775289285_235555000, data size: 460800, comm delay [164.9181]ms
[example-3] [WARN] [1775289286.120254846] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.24, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 193
[example-3] [WARN] [1775289287.128196271] [dnn_example_node]: Sub img fps: 30.48, Smart fps: 30.57, recved img time delay ms: 163, pre process time ms: 2, infer time ms: 3, post process time ms: 7, pipeline time ms: 177
[example-3] [WARN] [1775289288.145616770] [dnn_example_node]: Sub img fps: 30.36, Smart fps: 30.36, recved img time delay ms: 161, pre process time ms: 2, infer time ms: 3, post process time ms: 3, pipeline time ms: 170
[example-3] [WARN] [1775289288.437104916] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 1281, stamp: 1775289288_271215000, data size: 460800, comm delay [165.8736]ms
[example-3] [WARN] [1775289289.167881833] [dnn_example_node]: Sub img fps: 30.33, Smart fps: 30.33, recved img time delay ms: 163, pre process time ms: 2, infer time ms: 3, post process time ms: 2, pipeline time ms: 172
[example-3] [WARN] [1775289290.179907990] [dnn_example_node]: Sub img fps: 30.33, Smart fps: 29.97, recved img time delay ms: 165, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 192
[hobot_codec_republish-2] [WARN] [1775289290.183808670] [hobot_codec_decoder]: Pub img fps [30.30]
[example-3] [WARN] [1775289291.187095283] [dnn_example_node]: Sub img fps: 30.24, Smart fps: 30.60, recved img time delay ms: 161, pre process time ms: 3, infer time ms: 3, post process time ms: 7, pipeline time ms: 177
[example-3] [WARN] [1775289291.470184757] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 1373, stamp: 1775289291_306878000, data size: 460800, comm delay [163.2992]ms
[example-3] [WARN] [1775289292.214924652] [dnn_example_node]: Sub img fps: 30.16, Smart fps: 30.19, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 3, post process time ms: 6, pipeline time ms: 184
[example-3] [WARN] [1775289293.247468254] [dnn_example_node]: Sub img fps: 30.54, Smart fps: 30.21, recved img time delay ms: 166, pre process time ms: 6, infer time ms: 4, post process time ms: 13, pipeline time ms: 193
[example-3] [WARN] [1775289294.266635221] [dnn_example_node]: Sub img fps: 30.30, Smart fps: 30.42, recved img time delay ms: 162, pre process time ms: 5, infer time ms: 4, post process time ms: 12, pipeline time ms: 188
[example-3] [WARN] [1775289294.471275444] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 1464, stamp: 1775289294_306531000, data size: 460800, comm delay [164.7284]ms
^C[WARNING] [launch]: user interrupted with ctrl-c (SIGINT)
[image_transport_node-5] [INFO] [1775289294.926605474] [rclcpp]: signal_handler(SIGINT/SIGTERM)
[hobot_usb_cam-1] [WARN] [1775289294.929076039] [hobot_usb_cam]: Shutting down
[INFO] [hobot_codec_republish-2]: process has finished cleanly [pid 8166]
[INFO] [hobot_usb_cam-1]: process has finished cleanly [pid 8164]
[INFO] [image_transport_node-5]: process has finished cleanly [pid 8172]
[INFO] [websocket-4]: process has finished cleanly [pid 8170]
[ERROR] [example-3]: process has died [pid 8168, exit code -7, cmd ‘/opt/tros/humble/lib/dnn_node_example/example --ros-args --log-level warn --ros-args --params-file /tmp/launch_params_qnozsz4e --params-file /tmp/launch_params_313d81cd --params-file /tmp/launch_params_g_xmgmhx --params-file /tmp/launch_params_oqfnmone --params-file /tmp/launch_params_s87sp_1o’].
sunrise@ubuntu:~/yiqiang_ws$ export CAM_TYPE=usb
ros2 launch origincar_bringup usb_websocket_display.launch.py dnn_example_config_file:=/home/sunrise/yiqiang_ws/src/origincar/models/yolov8workconfig.json
[INFO] [launch]: All log files can be found below /home/sunrise/.ros/log/2026-04-04-15-55-31-939545-ubuntu-8741
[INFO] [launch]: Default logging verbosity is set to INFO
config_file_path is /opt/tros/humble/lib/hobot_usb_cam/config/usb_camera_calibration.yaml
Hobot shm pkg enables zero-copy with fastrtps profiles file: /opt/tros/humble/lib/hobot_shm/config/shm_fastdds.xml
Hobot shm pkg sets RMW_FASTRTPS_USE_QOS_FROM_XML: 1
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
webserver has launch
config_file_path is /opt/tros/humble/lib/hobot_usb_cam/config/usb_camera_calibration.yaml
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
env of RMW_FASTRTPS_USE_QOS_FROM_XML is 1 , ignore env setting
webserver has launch
[INFO] [hobot_usb_cam-1]: process started with pid [8758]
[INFO] [hobot_codec_republish-2]: process started with pid [8760]
[INFO] [example-3]: process started with pid [8762]
[INFO] [websocket-4]: process started with pid [8764]
[INFO] [image_transport_node-5]: process started with pid [8766]
[hobot_codec_republish-2] [WARN] [1775289332.632913947] [hobot_codec_decoder]: Parameters:
[hobot_codec_republish-2] sub_topic: /image
[hobot_codec_republish-2] pub_topic: /hbmem_img
[hobot_codec_republish-2] channel: 1
[hobot_codec_republish-2] in_mode: ros
[hobot_codec_republish-2] out_mode: shared_mem
[hobot_codec_republish-2] in_format: jpeg
[hobot_codec_republish-2] out_format: nv12
[hobot_codec_republish-2] jpg_quality: 60.00
[hobot_codec_republish-2] input_framerate: 30
[hobot_codec_republish-2] output_framerate: -1
[hobot_codec_republish-2] dump_output: false
[hobot_codec_republish-2] dump_file_prefix: ./dump_codec_output
[hobot_codec_republish-2] dump_frame_count: -1 (unlimited)
[hobot_codec_republish-2] [WARN] [1775289332.639453403] [HobotCodecImpl]: platform x5
[hobot_usb_cam-1] [WARN] [1775289332.768528460] [hobot_usb_cam]: framerate: 30
[hobot_usb_cam-1] [WARN] [1775289332.769075998] [hobot_usb_cam]: pixel_format_name: mjpeg
[hobot_usb_cam-1] [WARN] [1775289332.792788757] [hobot_usb_cam]: Camera calibration file: [/opt/tros/humble/lib/hobot_usb_cam/config/usb_camera_calibration.yaml] does not exist!
[hobot_usb_cam-1] If you need calibration msg, please make sure the calibration file path is correct and the calibration file exists!
[hobot_usb_cam-1] [WARN] [1775289332.875999786] [hobot_usb_cam]: This devices supproted formats:
[hobot_usb_cam-1] [WARN] [1775289332.876356159] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876425950] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876467867] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876507325] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876546074] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876584074] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876621699] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876659824] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876697157] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876734657] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876772156] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876808781] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876846114] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876883364] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876920822] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876957697] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.876994613] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877032030] [hobot_usb_cam]: Motion-JPEG: 1280 x 720 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877069196] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877155529] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877259611] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877300069] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877337944] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877375236] [hobot_usb_cam]: Motion-JPEG: 640 x 480 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877412694] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877450277] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877487610] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877525026] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877563359] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877600692] [hobot_usb_cam]: Motion-JPEG: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877637651] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877675317] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877713150] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877750775] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877788358] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877825608] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877863441] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877901274] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877938565] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.877975982] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878013606] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878051023] [hobot_usb_cam]: Motion-JPEG: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878088439] [hobot_usb_cam]: YUYV 4:2:2: 640 x 480 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878126189] [hobot_usb_cam]: YUYV 4:2:2: 640 x 480 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878164314] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878201272] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878349437] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878394895] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878433437] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878470728] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878508811] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878545894] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878583186] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878620394] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878657560] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878694560] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878731268] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878768976] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878806684] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878845892] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878883934] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878921100] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878958100] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.878995350] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879032516] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879070724] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879108057] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879145599] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879184265] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879221765] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879259265] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879296431] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879333639] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879370556] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879407847] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879444930] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879482263] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879519180] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879556513] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879593596] [hobot_usb_cam]: YUYV 4:2:2: 800 x 450 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879631096] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879669220] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879706387] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879743387] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879781303] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879819094] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (5 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879857094] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (30 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879894677] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (25 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879932094] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (20 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.879969802] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (15 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.880007051] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (10 Hz)
[hobot_usb_cam-1] [WARN] [1775289332.880045218] [hobot_usb_cam]: YUYV 4:2:2: 1920 x 1080 (5 Hz)
[example-3] [WARN] [1775289332.978107231] [dnn_example_node]: Parameter:
[example-3] feed_type(0:local, 1:sub): 1
[example-3] image: config/test.jpg
[example-3] image_type: 0
[example-3] dump_render_img: 0
[example-3] is_shared_mem_sub: 1
[example-3] config_file: /home/sunrise/yiqiang_ws/src/origincar/models/yolov8workconfig.json
[example-3] msg_pub_topic_name: hobot_dnn_detection
[example-3] info_msg_pub_topic_name: hobot_dnn_detection_info
[example-3] ros_img_topic_name: /image
[example-3] sharedmem_img_topic_name: /hbmem_img
[example-3] [WARN] [1775289332.979046017] [dnn_example_node]: Load [1] class types from file [/home/sunrise/yiqiang_ws/src/origincar/models/obstacles.list]
[example-3] [WARN] [1775289332.979207724] [dnn_example_node]: Parameter:
[example-3] model_file_name: /home/sunrise/yiqiang_ws/src/origincar/models/obstacle.bin
[example-3] model_name:
[example-3] [WARN] [1775289332.979314390] [dnn_example_node]: model_file_name_: /home/sunrise/yiqiang_ws/src/origincar/models/obstacle.bin, task_num: 4
[example-3] [BPU_PLAT]BPU Platform Version(1.3.6)! soc info(x5)
[example-3] [HBRT] set log level as 0. version = 3.15.55.0
[example-3] [DNN] Runtime version = 1.24.5_(3.15.55 HBRT)
[image_transport_node-5] [INFO] [1775289332.999904920] [Nv122BGR]: Nv122BGR
[hobot_codec_republish-2] [WARN] [1775289333.007826742] [hobot_codec_decoder]: New subscription discovered on topic ‘/hbmem_img’, requesting incompatible QoS. No messages will be sent to it. Last incompatible policy: RELIABILITY_QOS_POLICY
[websocket-4] [WARN] [1775289333.020006369] [websocket]:
[websocket-4] Parameter:
[websocket-4] image_topic: /image
[websocket-4] image_type: mjpeg
[websocket-4] only_show_image: 0
[websocket-4] smart_topic: hobot_dnn_detection
[websocket-4] output_fps: 0
[image_transport_node-5] [WARN] [1775289333.032139289] [Nv122BGR]: New publisher discovered on topic ‘/hbmem_img’, offering incompatible QoS. No messages will be sent to it. Last incompatible policy: RELIABILITY_QOS_POLICY
[example-3] [A][DNN][packed_model.cpp:247]Model [HorizonRT] The model builder version = 1.24.3
[example-3] [WARN] [1775289333.161270056] [dnn_example_node]: Get model name: obstacle from load model.
[example-3] [WARN] [1775289333.161455888] [dnn_example_node]: Create ai msg publisher with topic_name: hobot_dnn_detection
[example-3] [WARN] [1775289333.175273796] [dnn_example_node]: Create img hbmem_subscription with topic_name: /hbmem_img
[example-3] [WARN] [1775289333.837968017] [dnn_example_node]: Loaned messages are only safe with const ref subscription callbacks. If you are using any other kind of subscriptions, set the ROS_DISABLE_LOANED_MESSAGES environment variable to 1 (the default).
[example-3] [WARN] [1775289333.838403140] [dnn_example_node]: Recved img encoding: nv12, h: 480, w: 640, step: 640, index: 0, stamp: 1775289332_988594000, data size: 460800, comm delay [849.7865]ms
[ERROR] [example-3]: process has died [pid 8762, exit code -11, cmd ‘/opt/tros/humble/lib/dnn_node_example/example --ros-args --log-level warn --ros-args --params-file /tmp/launch_params_hh9bebbq --params-file /tmp/launch_params_puafwipi --params-file /tmp/launch_params_1bre_ws0 --params-file /tmp/launch_params_q7e8lta3 --params-file /tmp/launch_params_u2shejwc’].
[hobot_codec_republish-2] [WARN] [1775289337.671972416] [hobot_codec_decoder]: Pub img fps [23.80]
[websocket-4] [ERROR] [1775289338.051468459] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [WARN] [1775289342.686682782] [hobot_codec_decoder]: Pub img fps [30.32]
[websocket-4] [ERROR] [1775289343.051387156] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
[hobot_codec_republish-2] [WARN] [1775289347.699057598] [hobot_codec_decoder]: Pub img fps [30.33]
[websocket-4] [ERROR] [1775289348.051381452] [websocket]: Websocket did not receive AI data! Please check whether the AI data publisher still exists by ‘ros2 topic info hobot_dnn_detection’!
^C[WARNING] [launch]: user interrupted with ctrl-c (SIGINT)
[image_transport_node-5] [INFO] [1775289350.022333120] [rclcpp]: signal_handler(SIGINT/SIGTERM)
[hobot_usb_cam-1] [WARN] [1775289350.024781479] [hobot_usb_cam]: Shutting down
[INFO] [hobot_codec_republish-2]: process has finished cleanly [pid 8760]
[INFO] [hobot_usb_cam-1]: process has finished cleanly [pid 8758]
[INFO] [image_transport_node-5]: process has finished cleanly [pid 8766]
[INFO] [websocket-4]: process has finished cleanly [pid 8764]
sunrise@ubuntu:~/yiqiang_ws$ cat /home/sunrise/yiqiang_ws/src/origincar/models/yolov8workconfig.json
{
“model_file”: “/home/sunrise/yiqiang_ws/src/origincar/models/obstacle.bin”,
“dnn_Parser”: “yolov8”,
“model_output_count”: 6,
“reg_max”: 16,
“class_num”: 1,
“cls_names_list”: “/home/sunrise/yiqiang_ws/src/origincar/models/obstacles.list”,
“strides”: [8, 16, 32],
“score_threshold”: 0.25,
“nms_threshold”: 0.7,
“nms_top_k”: 300
}sunrise@ubuntu:~/yiqiang_ws$ sudo rdkos_info
================ RDK System Information Collection ================
[Hardware Model]:
D-Robotics RDK X5 V1.0 (Board Id = 302)
    temperature-->
            DDR      : 40.0 (C)
            BPU      : 38.5 (C)
            CPU      : 38.6 (C)
    cpu frequency-->
                  min(M)    cur(M)  max(M)
            cpu0: 300       1200    1500
            cpu1: 300       1200    1500
            cpu2: 300       1200    1500
            cpu3: 300       1500    1500
            cpu4: 300       1500    1500
            cpu5: 300       1200    1500
            cpu6: 300       1500    1500
            cpu7: 300       1500    1500
    bpu status information---->
                  min(M)    cur(M)  max(M)  ratio
            bpu0: 500       1000    1000    0
    ddr frequency information---->
                  min(M)    cur(M)  max(M)
            ddr:  266       4266    4266
    GPU gc8000 frequency information---->
                  min(M)    cur(M)  max(M)
            gc8000:  200    1000    1000
[RDK Kernel Version]:
Linux ubuntu 6.1.83 #4 SMP PREEMPT Fri Dec 19 10:54:38 CST 2025 aarch64 aarch64 aarch64 GNU/Linux
[RDK Miniboot Version]:
U-Boot 2022.10+ (Nov 22 2024 - 14:00:59 +0800)
[RDK Packages List]:
hobot-audio-config/unknown,now 3.0.2-20251208164616 arm64 [installed]
hobot-boot/unknown,now 3.0.10-20251219112904 arm64 [installed]
hobot-camera/unknown,now 3.1.0-20251208164524 arm64 [installed]
hobot-configs/unknown,now 3.1.2-20251208171048 arm64 [installed]
hobot-display/unknown,now 3.0.5-20251208164617 arm64 [installed]
hobot-dnn/unknown,now 3.0.1-20251208164739 arm64 [installed]
hobot-dtb/unknown,now 3.0.7-20251219113025 arm64 [installed]
hobot-io-samples/unknown,now 3.0.1-20251208164225 arm64 [installed]
hobot-io/unknown,now 3.1.2-20251219113023 arm64 [installed]
hobot-kernel-headers/unknown,now 3.0.3-20251219115258 arm64 [installed]
hobot-miniboot/unknown,now 3.0.8-20251208164400 arm64 [installed]
hobot-models-basic/unknown,now 1.2.0 arm64 [installed]
hobot-multimedia-dev/unknown,now 3.0.2-20251208164619 arm64 [installed]
hobot-multimedia-samples/unknown,now 3.1.0-20251208164621 arm64 [installed]
hobot-multimedia/unknown,now 3.0.4-20251208164341 arm64 [installed]
hobot-sp-samples/unknown,now 3.0.5-20251208164749 arm64 [installed]
hobot-spdev/unknown,now 3.0.8-20251208164547 arm64 [installed]
hobot-utils/unknown,now 3.0.6-20251208164617 arm64 [installed]
hobot-wifi/unknown,now 3.0.3-20260211192055 arm64 [installed]
[RDK Packages List]:
tros-humble-ai-msgs/unknown,now 2.0.1-jammy.20241225.032050 arm64 [installed]
tros-humble-audio-control/unknown,now 2.0.1-jammy.20250228.035949 arm64 [installed,automatic]
tros-humble-audio-msg/unknown,now 2.0.1-jammy.20250425.105023 arm64 [installed]
tros-humble-audio-tracking/unknown,now 2.1.0-jammy.20250228.040121 arm64 [installed,automatic]
tros-humble-base/unknown,now 2.4.5-jammy.20251028.175810 arm64 [installed]
tros-humble-body-tracking/unknown,now 2.1.1-jammy.20241225.040923 arm64 [installed]
tros-humble-chatbot/unknown 0.1.0-20240822101628 arm64
tros-humble-clip-encode-image/unknown,now 0.2.0-jammy.20241225.032737 arm64 [installed]
tros-humble-clip-encode-text/unknown,now 0.2.0-jammy.20241225.024337 arm64 [installed]
tros-humble-clip-manage/unknown,now 0.2.0-jammy.20241225.024351 arm64 [installed]
tros-humble-clip-msgs/unknown,now 0.2.0-jammy.20241225.024229 arm64 [installed]
tros-humble-dnn-benchmark-example/unknown,now 2.4.0-jammy.20251028.154809 arm64 [installed]
tros-humble-dnn-node-example/unknown,now 2.5.8-jammy.20251028.172948 arm64 [installed]
tros-humble-dnn-node-sample/unknown,now 2.3.2-jammy.20251028.173231 arm64 [installed]
tros-humble-dnn-node/unknown,now 2.5.9-jammy.20251114.092352 arm64 [installed]
tros-humble-dstereo-occnet/unknown,now 1.0.2-jammy.20251028.230248 arm64 [installed,automatic]
tros-humble-elevation-net/unknown,now 2.2.1-jammy.20241225.034317 arm64 [installed]
tros-humble-face-age-detection/unknown,now 2.3.1-jammy.20241225.033025 arm64 [installed]
tros-humble-face-landmarks-detection/unknown,now 2.3.1-jammy.20241225.033459 arm64 [installed]
tros-humble-faceid/unknown 0.1.0-jammy.20251216.145515 arm64
tros-humble-first-node/unknown 0.0.0-20240822101706 arm64
tros-humble-gesture-control/unknown,now 2.1.0-jammy.20241225.041130 arm64 [installed]
tros-humble-hand-gesture-detection/unknown,now 2.4.1-jammy.20241225.040702 arm64 [installed]
tros-humble-hand-lmk-detection/unknown,now 2.4.1-jammy.20241225.040439 arm64 [installed]
tros-humble-hbm-img-msgs/unknown,now 2.0.0-jammy.20241225.031409 arm64 [installed]
tros-humble-hobot-arm/unknown 2.0.0-20240822101204 arm64
tros-humble-hobot-audio/unknown,unknown,now 2.3.5-jammy.20250918.101554 arm64 [installed,automatic]
tros-humble-hobot-cartographer/unknown 0.0.1-20240822101611 arm64
tros-humble-hobot-chatbot/unknown 2.0.1-jammy.20241225.035416 arm64
tros-humble-hobot-codec/unknown,now 2.3.4-jammy.20251105.074330 arm64 [installed]
tros-humble-hobot-cv/unknown,now 2.3.4-jammy.20251105.073603 arm64 [installed]
tros-humble-hobot-dosod/unknown,now 0.1.0-jammy.20250108.034233 arm64 [installed,automatic]
tros-humble-hobot-falldown-detection/unknown,now 2.0.0-jammy.20241225.040324 arm64 [installed]
tros-humble-hobot-hdmi/unknown,unknown,now 2.4.2-jammy.20241127.083620 arm64 [installed]
tros-humble-hobot-image-publisher/unknown,now 2.2.1-jammy.20250425.114211 arm64 [installed]
tros-humble-hobot-llamacpp/unknown,now 0.3.0-jammy.20250728.125950 arm64 [installed,automatic]
tros-humble-hobot-llm/unknown 2.2.0-jammy.20241225.023654 arm64
tros-humble-hobot-mot/unknown,now 2.0.2-jammy.20241225.024808 arm64 [installed]
tros-humble-hobot-rtsp-client/unknown,now 1.0.2-jammy.20250428.105340 arm64 [installed]
tros-humble-hobot-shm/unknown,now 0.0.1-jammy.20241225.030528 arm64 [installed]
tros-humble-hobot-stereo-usb-cam/unknown 2.1.0-jammy.20240816.141027 arm64
tros-humble-hobot-stereonet-render/unknown 2.0.1-jammy.20240816.143408 arm64
tros-humble-hobot-stereonet-utils/unknown,now 2.3.1-jammy.20251028.155900 arm64 [installed]
tros-humble-hobot-stereonet/unknown,now 2.4.5-jammy.20251028.160634 arm64 [installed]
tros-humble-hobot-tts/unknown 2.0.6-jammy.20250428.105805 arm64
tros-humble-hobot-usb-cam/unknown,now 2.3.0-jammy.20250425.110259 arm64 [installed]
tros-humble-hobot-vio/unknown,now 2.1.1-jammy.20241225.023850 arm64 [installed]
tros-humble-hobot-visualization/unknown,now 2.0.3-jammy.20250425.114100 arm64 [installed]
tros-humble-hobot-yolo-world/unknown,now 0.4.1-jammy.20241225.041535 arm64 [installed]
tros-humble-hobot-zed-cam/unknown,now 2.3.3-jammy.20250425.104612 arm64 [installed,automatic]
tros-humble-img-msgs/unknown,now 2.0.0-jammy.20241225.031324 arm64 [installed]
tros-humble-imu-sensor/unknown,now 2.0.1-jammy.20241225.030258 arm64 [installed]
tros-humble-ldlidar-ros2/unknown 1.0.0-20240822101535 arm64
tros-humble-line-follower-model/unknown 2.0.0-jammy.20240821.150053 arm64
tros-humble-mipi-cam/unknown,now 2.4.0-jammy.20251208.035201 arm64 [installed]
tros-humble-mono-edgesam/unknown,now 0.1.3-jammy.20250718.095719 arm64 [installed,automatic]
tros-humble-mono-mobilesam/unknown,now 0.2.0-jammy.20241225.034034 arm64 [installed]
tros-humble-mono-pwcnet/unknown,now 0.1.0-jammy.20241225.033248 arm64 [installed]
tros-humble-mono2d-body-detection/unknown,now 2.4.1-jammy.20241225.040107 arm64 [installed]
tros-humble-mono2d-trash-detection/unknown,now 2.4.0-jammy.20241225.035918 arm64 [installed]
tros-humble-mono3d-indoor-detection/unknown,now 2.2.1-jammy.20241225.041312 arm64 [installed]
tros-humble-orb-slam3-example-ros2/unknown 2.3.1-jammy.20241122.161842 arm64
tros-humble-orb-slam3/unknown 2.3.0-jammy.20241120.074512 arm64
tros-humble-originbot-base/unknown 0.0.0-20240822101336 arm64
tros-humble-originbot-msgs/unknown 0.0.0-20240822101300 arm64
tros-humble-parking-perception/unknown,now 2.1.0-jammy.20240816.144347 arm64 [installed]
tros-humble-parking-search/unknown,now 2.1.0-jammy.20241225.032300 arm64 [installed]
tros-humble-performance-test/unknown 2.1.0-jammy.20241127.065446 arm64
tros-humble-racing-control/unknown 2.0.0-20240822101647 arm64
tros-humble-racing-image-collect/unknown 0.0.0-20240822101240 arm64
tros-humble-racing-light-detection-cv/unknown 0.0.0-20240822101554 arm64
tros-humble-recorder-node/unknown 2.1.0-jammy.20241225.024033 arm64
tros-humble-reid/unknown,now 0.1.0-jammy.20250718.090315 arm64 [installed,automatic]
tros-humble-ros-workspace/unknown,now 1.0.3-jammy.20240410.033708 arm64 [installed]
tros-humble-sensevoice-ros2/unknown 1.1.0-jammy.20251216.095038 arm64
tros-humble-serial/unknown 1.2.1-20240822101317 arm64
tros-humble-sllidar-ros2/unknown 1.0.1-20240822101516 arm64
tros-humble-trigger-node-example/unknown 2.1.0-jammy.20241225.032624 arm64
tros-humble-trigger-node/unknown 2.1.0-jammy.20241225.024119 arm64
tros-humble-tros-lowpass-filter/unknown,now 0.0.1-jammy.20241225.033734 arm64 [installed]
tros-humble-tros-perception-fusion-msgs/unknown,now 0.0.1-jammy.20241225.024840 arm64 [installed]
tros-humble-tros-perception-fusion/unknown,now 0.0.1-jammy.20241225.033858 arm64 [installed]
tros-humble-websocket/unknown,now 2.3.2-jammy.20250425.113230 arm64 [installed]
tros-humble-yahboom-sunrise-robot-lib/unknown 0.0.0-20240822101356 arm64
tros-humble-yahboomcar-base-node/unknown 0.0.0-20240822101438 arm64
tros-humble-yahboomcar-bringup/unknown 0.0.0-20240822101457 arm64
tros-humble-yahboomcar-description/unknown 0.0.0-20240822101414 arm64
tros-humble-ydlidar-ros2-driver/unknown 1.0.1-20240822090807 arm64
tros-humble/unknown,now 2.4.5-jammy.20251028.175825 arm64 [installed]
[RDK Kernel Module List]:
Module Size Used by
usb_f_ecm 24576 2
usb_f_mass_storage 65536 2
rfcomm 86016 16
vs_drm 172032 1
vs_x5_syscon_bridge 16384 0
vio_n2d 274432 1 vs_drm
galcore 380928 0
bnep 28672 2
snd_soc_hobot_sound_duplex_host 24576 0
snd_soc_simple_card_utils 28672 1 snd_soc_hobot_sound_duplex_host
es8311 45056 0
designware_i2s 24576 2
rtc_hpu3501 20480 1
usb_f_rndis 40960 2
u_ether 28672 2 usb_f_rndis,usb_f_ecm
libcomposite 69632 14 usb_f_rndis,usb_f_mass_storage,usb_f_ecm
leds_gpio 16384 0
led_class 20480 1 leds_gpio
bpu_hw_io_x5 24576 0
bpu_cores 28672 1 bpu_hw_io_x5
bpu_framework 77824 2 bpu_hw_io_x5,bpu_cores
hobot_lpwm 45056 0
hobot_isi_sensor 45056 0
hobot_gdc 36864 0
hobot_deserial 45056 0
vs_vse_nat 61440 0
vs_dw_crc 16384 2 hobot_gdc,vs_vse_nat
vs_isp_nat 98304 1 vs_vse_nat
hobot_mipidbg 28672 0
hobot_mipicsi 126976 1 hobot_mipidbg
hobot_camsys 36864 2 hobot_mipicsi,hobot_gdc
hobot_mipiphy 49152 2 hobot_mipidbg,hobot_mipicsi
hobot_sensor 344064 1 hobot_isi_sensor
vs_sif_nat 69632 0
vs_ops_nat 16384 3 vs_isp_nat,vs_sif_nat,vs_vse_nat
vs_cam_pulse 16384 1 vs_sif_nat
hobot_vin_vcon 45056 0
hobot_vin_vnode 45056 4 hobot_mipicsi,vs_sif_nat,hobot_vin_vcon,hobot_lpwm
hobot_osd 73728 0
hobot_jpu 69632 0
hobot_vpu 122880 0
hobot_codec_vnode 32768 0
hobot_vio_common 114688 14 hobot_isi_sensor,vio_n2d,hobot_deserial,hobot_camsys,vs_isp_nat,hobot_vin_vnode,hobot_gdc,hobot_osd,hobot_codec_vnode,vs_sif_nat,hobot_vin_vcon,vs_vse_nat,hobot_sensor,hobot_lpwm
vs_csi_wrapper 16384 0
vs_cam_ctrl 16384 4 vs_isp_nat,hobot_gdc,vs_sif_nat,vs_vse_nat
vs_isc 32768 13 vs_isp_nat,vs_sif_nat,vs_vse_nat
binfmt_misc 24576 1
aic8800_fdrv 475136 0
cdc_acm 40960 0
cfg80211 389120 1 aic8800_fdrv
aic8800_bsp 90112 1 aic8800_fdrv
tcan4x5x 16384 0
m_can 32768 1 tcan4x5x
can_dev 40960 1 m_can
sii902x 24576 0
i2c_mux 16384 1 sii902x
spidev 24576 0
drm_kms_helper 172032 3 sii902x,vs_x5_syscon_bridge,vs_drm
syscopyarea 16384 1 drm_kms_helper
sysfillrect 16384 1 drm_kms_helper
sysimgblt 16384 1 drm_kms_helper
snd_soc_es8326 45056 1
fb_sys_fops 16384 1 drm_kms_helper
evdev 24576 3
sch_fq_codel 20480 264
hb_bl 16384 0
goodix_ts 32768 0
panel_waveshare_dsi 16384 0
ft5406 20480 0
panel_wh_cm480 16384 0
uvcvideo 106496 0
videobuf2_vmalloc 20480 1 uvcvideo
videobuf2_memops 20480 1 videobuf2_vmalloc
videobuf2_v4l2 32768 1 uvcvideo
videobuf2_common 53248 4 videobuf2_vmalloc,videobuf2_v4l2,uvcvideo,videobuf2_memops
hci_uart 49152 1
btrtl 28672 1 hci_uart
btbcm 20480 0
bluetooth 790528 42 btrtl,hci_uart,btbcm,bnep,rfcomm
rfkill 32768 7 bluetooth,cfg80211
fuse 131072 1
[Kernel Log]:
Apr 4 15:55:33 ubuntu kernel: [ 965.516275] [VPF ops]:[L1639][vs-vse0_cap0][S0][C0] vpf_video_start: done start_cnt 1
Apr 4 15:55:33 ubuntu kernel: [ 965.516289] vse_video_streamon ctx.sink_online_en=0
Apr 4 15:55:33 ubuntu kernel: [ 965.516421] [VPF ops]:[L1639][vs-vse0_src][S0][C0] vpf_video_start: done start_cnt 2
Apr 4 15:55:33 ubuntu kernel: [ 965.547770] [VPF ops]:[L2492][flow][S0] vpf_subdev_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547797] [VPF ops]:[L2554][flow] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547817] [VPF ops]:[L81][S0][vse0] vpf_wait_vnode_shot: cnt 10
Apr 4 15:55:33 ubuntu kernel: [ 965.547901] [VPF ops]:[L1554][vs-vse0_src][S0][C0] vpf_video_stop: done start_cnt 1
Apr 4 15:55:33 ubuntu kernel: [ 965.547916] [VPF ops]:[L1554][vs-vse0_cap0][S0][C0] vpf_video_stop: done start_cnt 0
Apr 4 15:55:33 ubuntu kernel: [ 965.547925] [VPF ops]:[L154][S0][vse0] vpf_safety_close: sudden close
Apr 4 15:55:33 ubuntu kernel: [ 965.547933] [VPF ops]:[L210][vs-vse0_cap5][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.547943] [VPF ops]:[L2554][vs-vse0_cap5] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547954] [VPF ops]:[L210][vs-vse0_cap4][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.547963] [VPF ops]:[L2554][vs-vse0_cap4] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547973] [VPF ops]:[L210][vs-vse0_cap3][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.547982] [VPF ops]:[L2554][vs-vse0_cap3] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547991] [VPF ops]:[L210][vs-vse0_cap2][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.548000] [VPF ops]:[L2554][vs-vse0_cap2] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.548011] [VPF ops]:[L210][vs-vse0_cap1][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.548019] [VPF ops]:[L2554][vs-vse0_cap1] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.548031] [VPF ops]:[L210][vs-vse0_cap0][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.548082] [VPF ops]:[L2554][vs-vse0_cap0] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.549476] [VIO node]:[L141][vse0] vio_group_task_stop: done
Apr 4 15:55:33 ubuntu kernel: [ 965.549490] [VPF ops]:[L210][vs-vse0_src][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.549499] vse_nat_close set vse state to CLOSED
Apr 4 15:55:33 ubuntu kernel: [ 965.550218] [VPF ops]:[L1732][vs-vse0_src][S0][C0] vpf_chain_del_vnode: done
Apr 4 15:55:33 ubuntu kernel: [ 965.550231] [VPF ops]:[L2554][vs-vse0_src] vpf_device_close: done
Apr 4 15:55:50 ubuntu kernel: [ 981.698270] hobot_jpu_dev: [JPUDRV]jpu_release_internal_res:2600: finish jpu_release_internal_res, current_pid=8860, tgid=8760
Apr 4 15:55:50 ubuntu kernel: [ 981.698503] hobot_jpu_dev: [JPUDRV]jpu_close_instance:1646: [-]JDI_IOCTL_CLOSE_INSTANCE inst_idx=0, s_jpu_open_ref_count=0, inst_open_count=0, current_pid=8760, tgid=8760
Apr 4 15:55:50 ubuntu kernel: [ 981.701680] hobot_jpu_dev: [JPUDRV]jpu_release_internal_res:2600: finish jpu_release_internal_res, current_pid=8760, tgid=8760
Apr 4 15:55:50 ubuntu kernel: [ 981.712695] uvcvideo 1-1.4:1.1: Failed to resubmit video URB (-1).
[System Log]:
Apr 4 15:55:33 ubuntu kernel: [ 965.516421] [VPF ops]:[L1639][vs-vse0_src][S0][C0] vpf_video_start: done start_cnt 2
Apr 4 15:55:33 ubuntu kernel: [ 965.547770] [VPF ops]:[L2492][flow][S0] vpf_subdev_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547797] [VPF ops]:[L2554][flow] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547817] [VPF ops]:[L81][S0][vse0] vpf_wait_vnode_shot: cnt 10
Apr 4 15:55:33 ubuntu kernel: [ 965.547901] [VPF ops]:[L1554][vs-vse0_src][S0][C0] vpf_video_stop: done start_cnt 1
Apr 4 15:55:33 ubuntu kernel: [ 965.547916] [VPF ops]:[L1554][vs-vse0_cap0][S0][C0] vpf_video_stop: done start_cnt 0
Apr 4 15:55:33 ubuntu kernel: [ 965.547925] [VPF ops]:[L154][S0][vse0] vpf_safety_close: sudden close
Apr 4 15:55:33 ubuntu kernel: [ 965.547933] [VPF ops]:[L210][vs-vse0_cap5][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.547943] [VPF ops]:[L2554][vs-vse0_cap5] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547954] [VPF ops]:[L210][vs-vse0_cap4][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.547963] [VPF ops]:[L2554][vs-vse0_cap4] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547973] [VPF ops]:[L210][vs-vse0_cap3][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.547982] [VPF ops]:[L2554][vs-vse0_cap3] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.547991] [VPF ops]:[L210][vs-vse0_cap2][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.548000] [VPF ops]:[L2554][vs-vse0_cap2] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.548011] [VPF ops]:[L210][vs-vse0_cap1][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.548019] [VPF ops]:[L2554][vs-vse0_cap1] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.548031] [VPF ops]:[L210][vs-vse0_cap0][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.548082] [VPF ops]:[L2554][vs-vse0_cap0] vpf_device_close: done
Apr 4 15:55:33 ubuntu kernel: [ 965.549476] [VIO node]:[L141][vse0] vio_group_task_stop: done
Apr 4 15:55:33 ubuntu kernel: [ 965.549490] [VPF ops]:[L210][vs-vse0_src][S0][C0] vpf_vdev_close: refcount 0
Apr 4 15:55:33 ubuntu kernel: [ 965.549499] vse_nat_close set vse state to CLOSED
Apr 4 15:55:33 ubuntu kernel: [ 965.550218] [VPF ops]:[L1732][vs-vse0_src][S0][C0] vpf_chain_del_vnode: done
Apr 4 15:55:33 ubuntu kernel: [ 965.550231] [VPF ops]:[L2554][vs-vse0_src] vpf_device_close: done
Apr 4 15:55:50 ubuntu kernel: [ 981.698270] hobot_jpu_dev: [JPUDRV]jpu_release_internal_res:2600: finish jpu_release_internal_res, current_pid=8860, tgid=8760
Apr 4 15:55:50 ubuntu kernel: [ 981.698503] hobot_jpu_dev: [JPUDRV]jpu_close_instance:1646: [-]JDI_IOCTL_CLOSE_INSTANCE inst_idx=0, s_jpu_open_ref_count=0, inst_open_count=0, current_pid=8760, tgid=8760
Apr 4 15:55:50 ubuntu kernel: [ 981.701680] hobot_jpu_dev: [JPUDRV]jpu_release_internal_res:2600: finish jpu_release_internal_res, current_pid=8760, tgid=8760
Apr 4 15:55:50 ubuntu kernel: [ 981.712695] uvcvideo 1-1.4:1.1: Failed to resubmit video URB (-1).
Apr 4 15:56:14 ubuntu ntpd[972]: 185.125.190.56 local addr 192.168.10.100 →
Apr 4 15:56:45 ubuntu ntpd[972]: 108.59.2.24 local addr 192.168.10.100 →
[Journal Log]:
4月 04 15:56:51 ubuntu sudo[9147]: pam_unix(sudo:session): session opened for user root(uid=0) by (uid=1000)
4月 04 15:56:51 ubuntu sudo[9147]: sunrise : TTY=pts/0 ; PWD=/home/sunrise/yiqiang_ws ; USER=root ; COMMAND=/usr/bin/rdkos_info
4月 04 15:56:45 ubuntu ntpd[972]: 108.59.2.24 local addr 192.168.10.100 →
4月 04 15:56:14 ubuntu ntpd[972]: 185.125.190.56 local addr 192.168.10.100 →
4月 04 15:55:50 ubuntu kernel: uvcvideo 1-1.4:1.1: Failed to resubmit video URB (-1).
4月 04 15:55:50 ubuntu kernel: hobot_jpu_dev: [JPUDRV]jpu_release_internal_res:2600: finish jpu_release_internal_res, current_pid=8760, tgid=8760
4月 04 15:55:50 ubuntu kernel: hobot_jpu_dev: [JPUDRV]jpu_close_instance:1646: [-]JDI_IOCTL_CLOSE_INSTANCE inst_idx=0, s_jpu_open_ref_count=0, inst_open_count=0, current_pid=8760, tgid=8760
4月 04 15:55:50 ubuntu kernel: hobot_jpu_dev: [JPUDRV]jpu_release_internal_res:2600: finish jpu_release_internal_res, current_pid=8860, tgid=8760
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L2554][vs-vse0_src] vpf_device_close: done
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L1732][vs-vse0_src][S0][C0] vpf_chain_del_vnode: done
4月 04 15:55:33 ubuntu kernel: vse_nat_close set vse state to CLOSED
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L210][vs-vse0_src][S0][C0] vpf_vdev_close: refcount 0
4月 04 15:55:33 ubuntu kernel: [VIO node]:[L141][vse0] vio_group_task_stop: done
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L2554][vs-vse0_cap0] vpf_device_close: done
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L210][vs-vse0_cap0][S0][C0] vpf_vdev_close: refcount 0
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L2554][vs-vse0_cap1] vpf_device_close: done
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L210][vs-vse0_cap1][S0][C0] vpf_vdev_close: refcount 0
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L2554][vs-vse0_cap2] vpf_device_close: done
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L210][vs-vse0_cap2][S0][C0] vpf_vdev_close: refcount 0
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L2554][vs-vse0_cap3] vpf_device_close: done
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L210][vs-vse0_cap3][S0][C0] vpf_vdev_close: refcount 0
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L2554][vs-vse0_cap4] vpf_device_close: done
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L210][vs-vse0_cap4][S0][C0] vpf_vdev_close: refcount 0
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L2554][vs-vse0_cap5] vpf_device_close: done
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L210][vs-vse0_cap5][S0][C0] vpf_vdev_close: refcount 0
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L154][S0][vse0] vpf_safety_close: sudden close
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L1554][vs-vse0_cap0][S0][C0] vpf_video_stop: done start_cnt 0
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L1554][vs-vse0_src][S0][C0] vpf_video_stop: done start_cnt 1
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L81][S0][vse0] vpf_wait_vnode_shot: cnt 10
4月 04 15:55:33 ubuntu kernel: [VPF ops]:[L2554][flow] vpf_device_close: done
sunrise@ubuntu:~/yiqiang_ws$
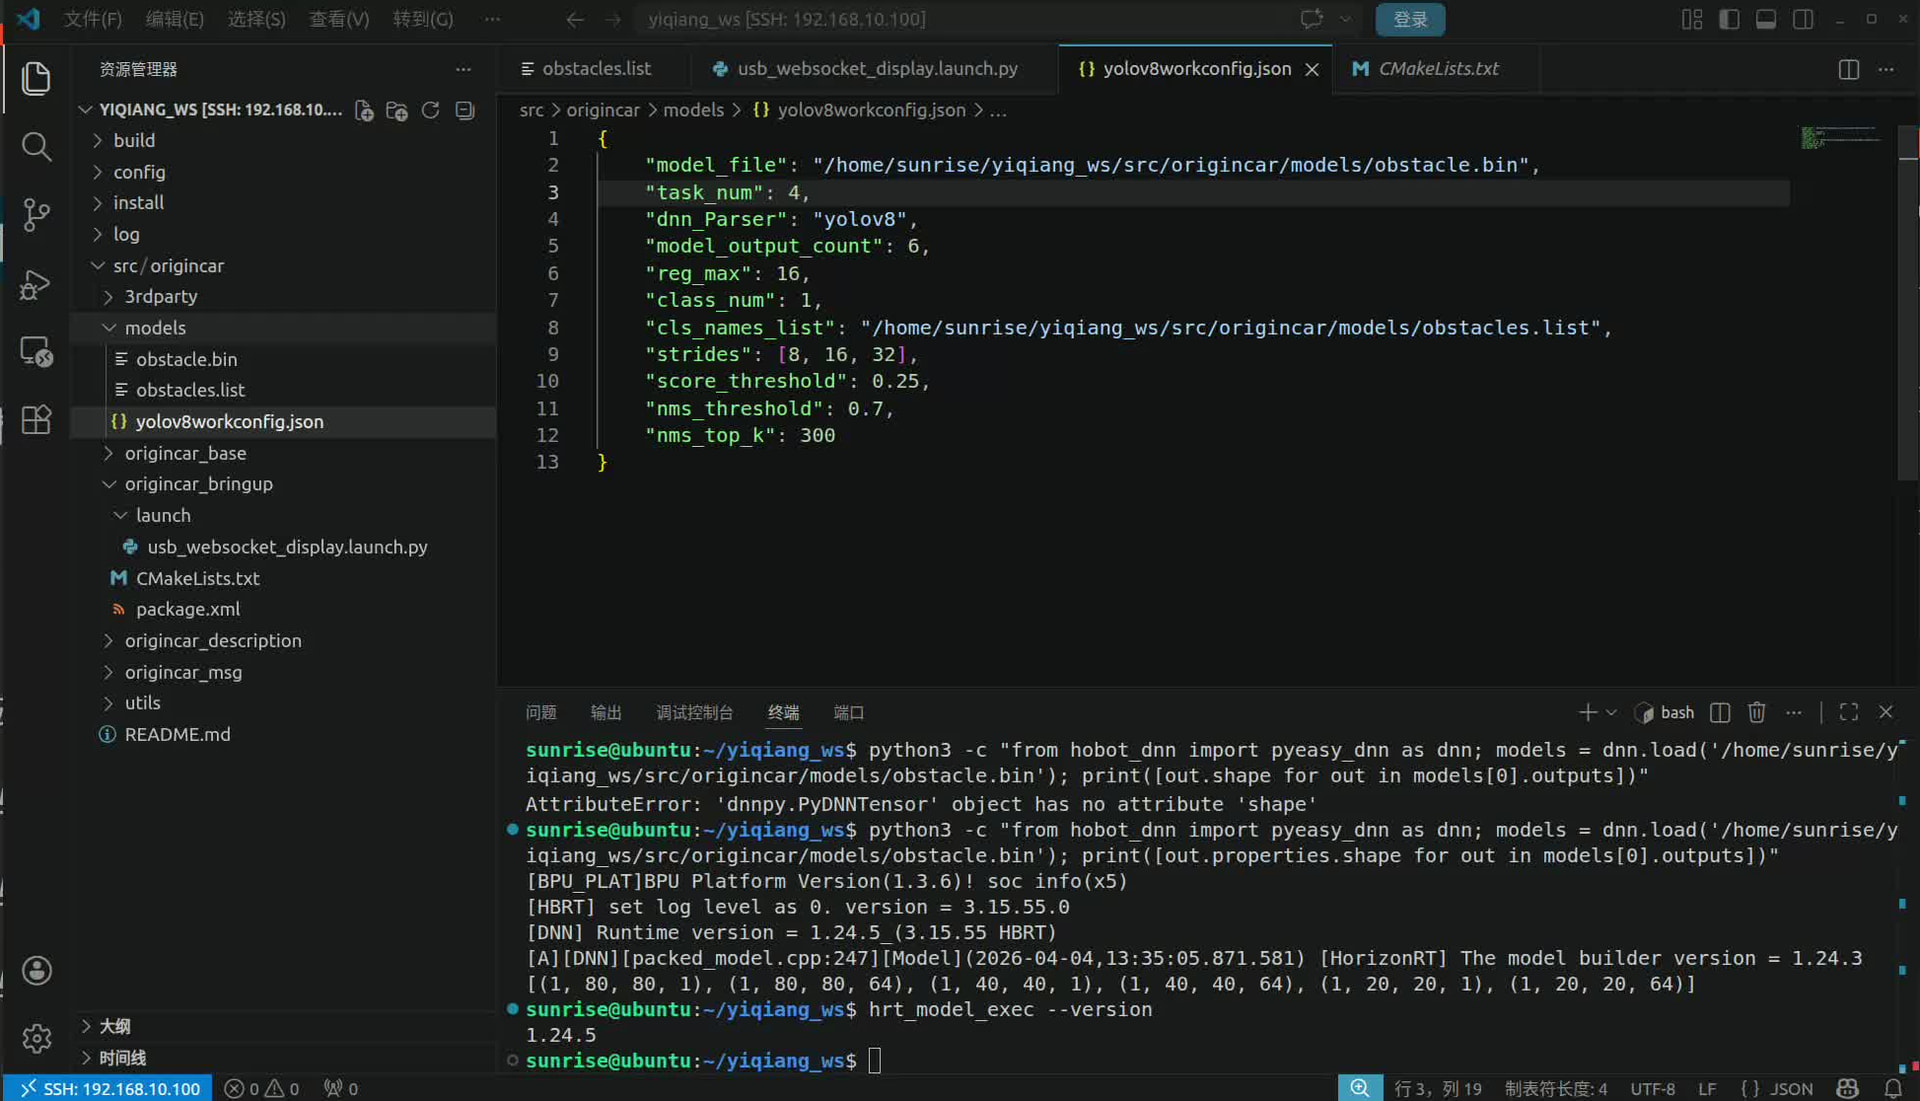
 6个输出,NCHW格式
 仍然 crash (exit code -11)